Legged robotics
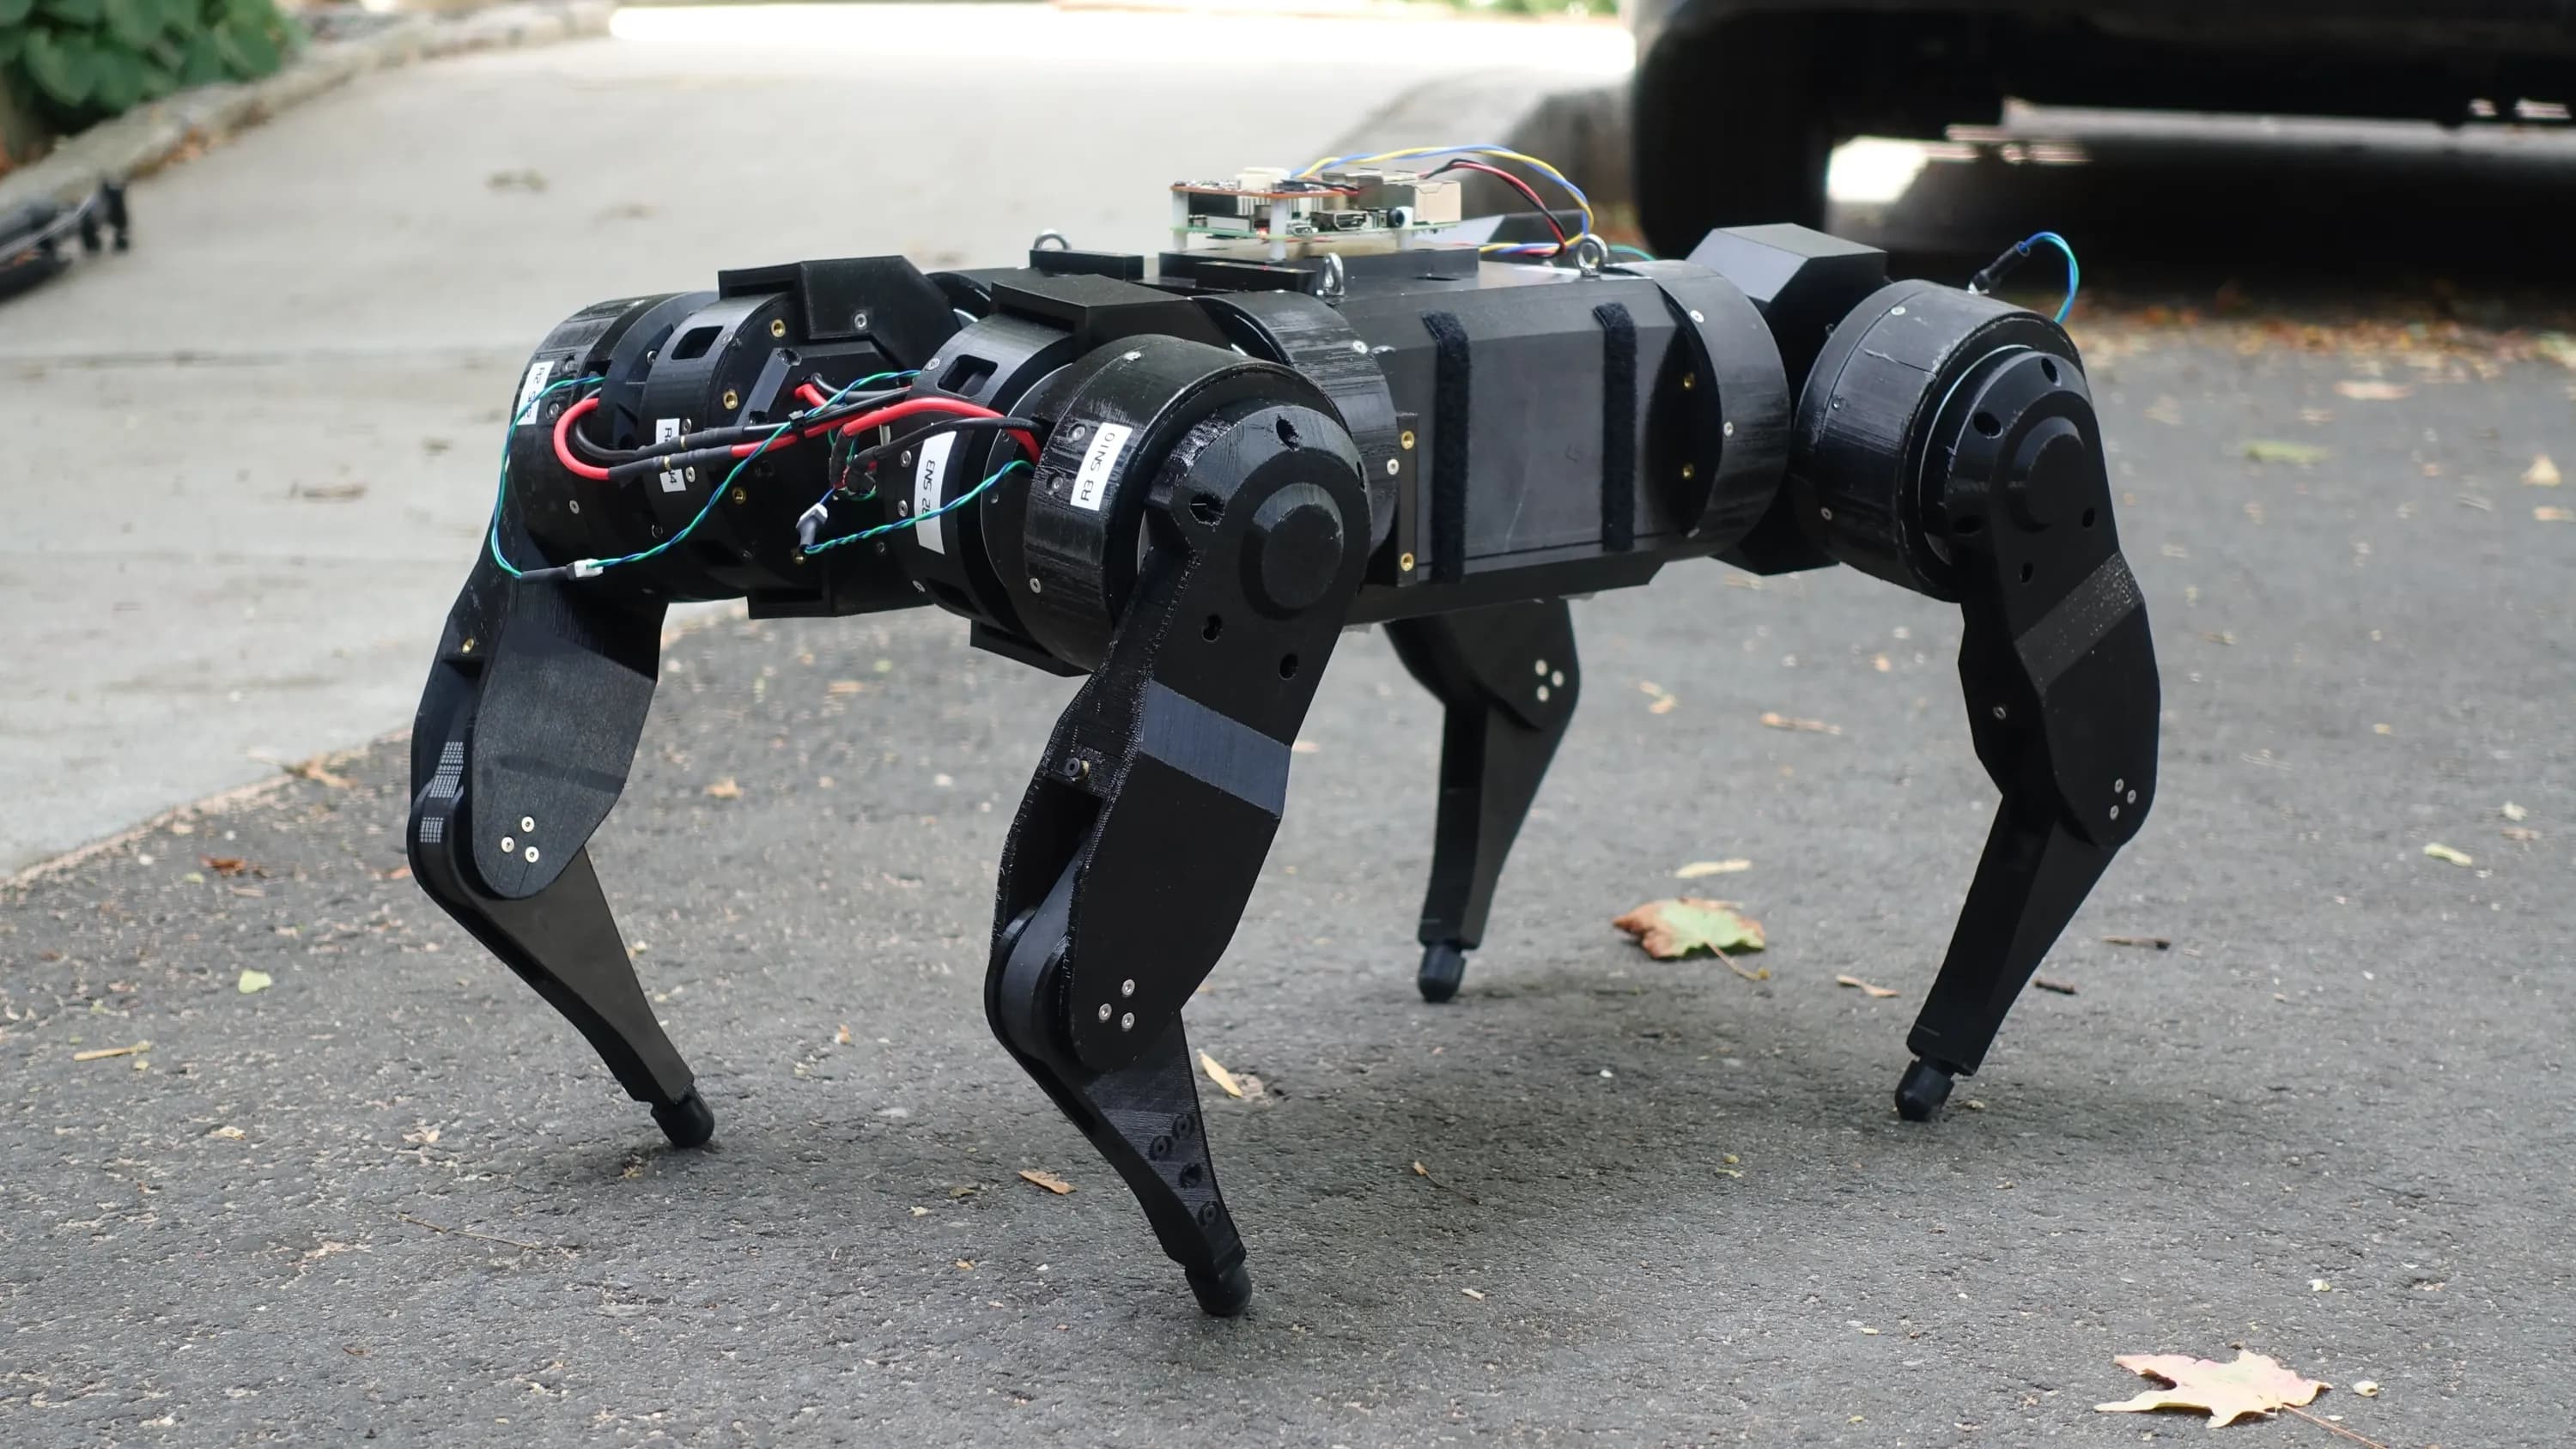
Quadruped Platform
A four-legged machine used to work through actuation, gait and balance — and to give the control problem a physical body to fail against.
Projects
Platforms we build to work through problems properly — legged robots, ground vehicles, aircraft and the occasional machine that exists only because someone wanted to know whether it would work.
Descriptions here are kept broad on purpose. These are working platforms rather than finished products, and we would rather say less than claim more than a machine has actually done.
Legged robotics
A four-legged machine used to work through actuation, gait and balance — and to give the control problem a physical body to fail against.
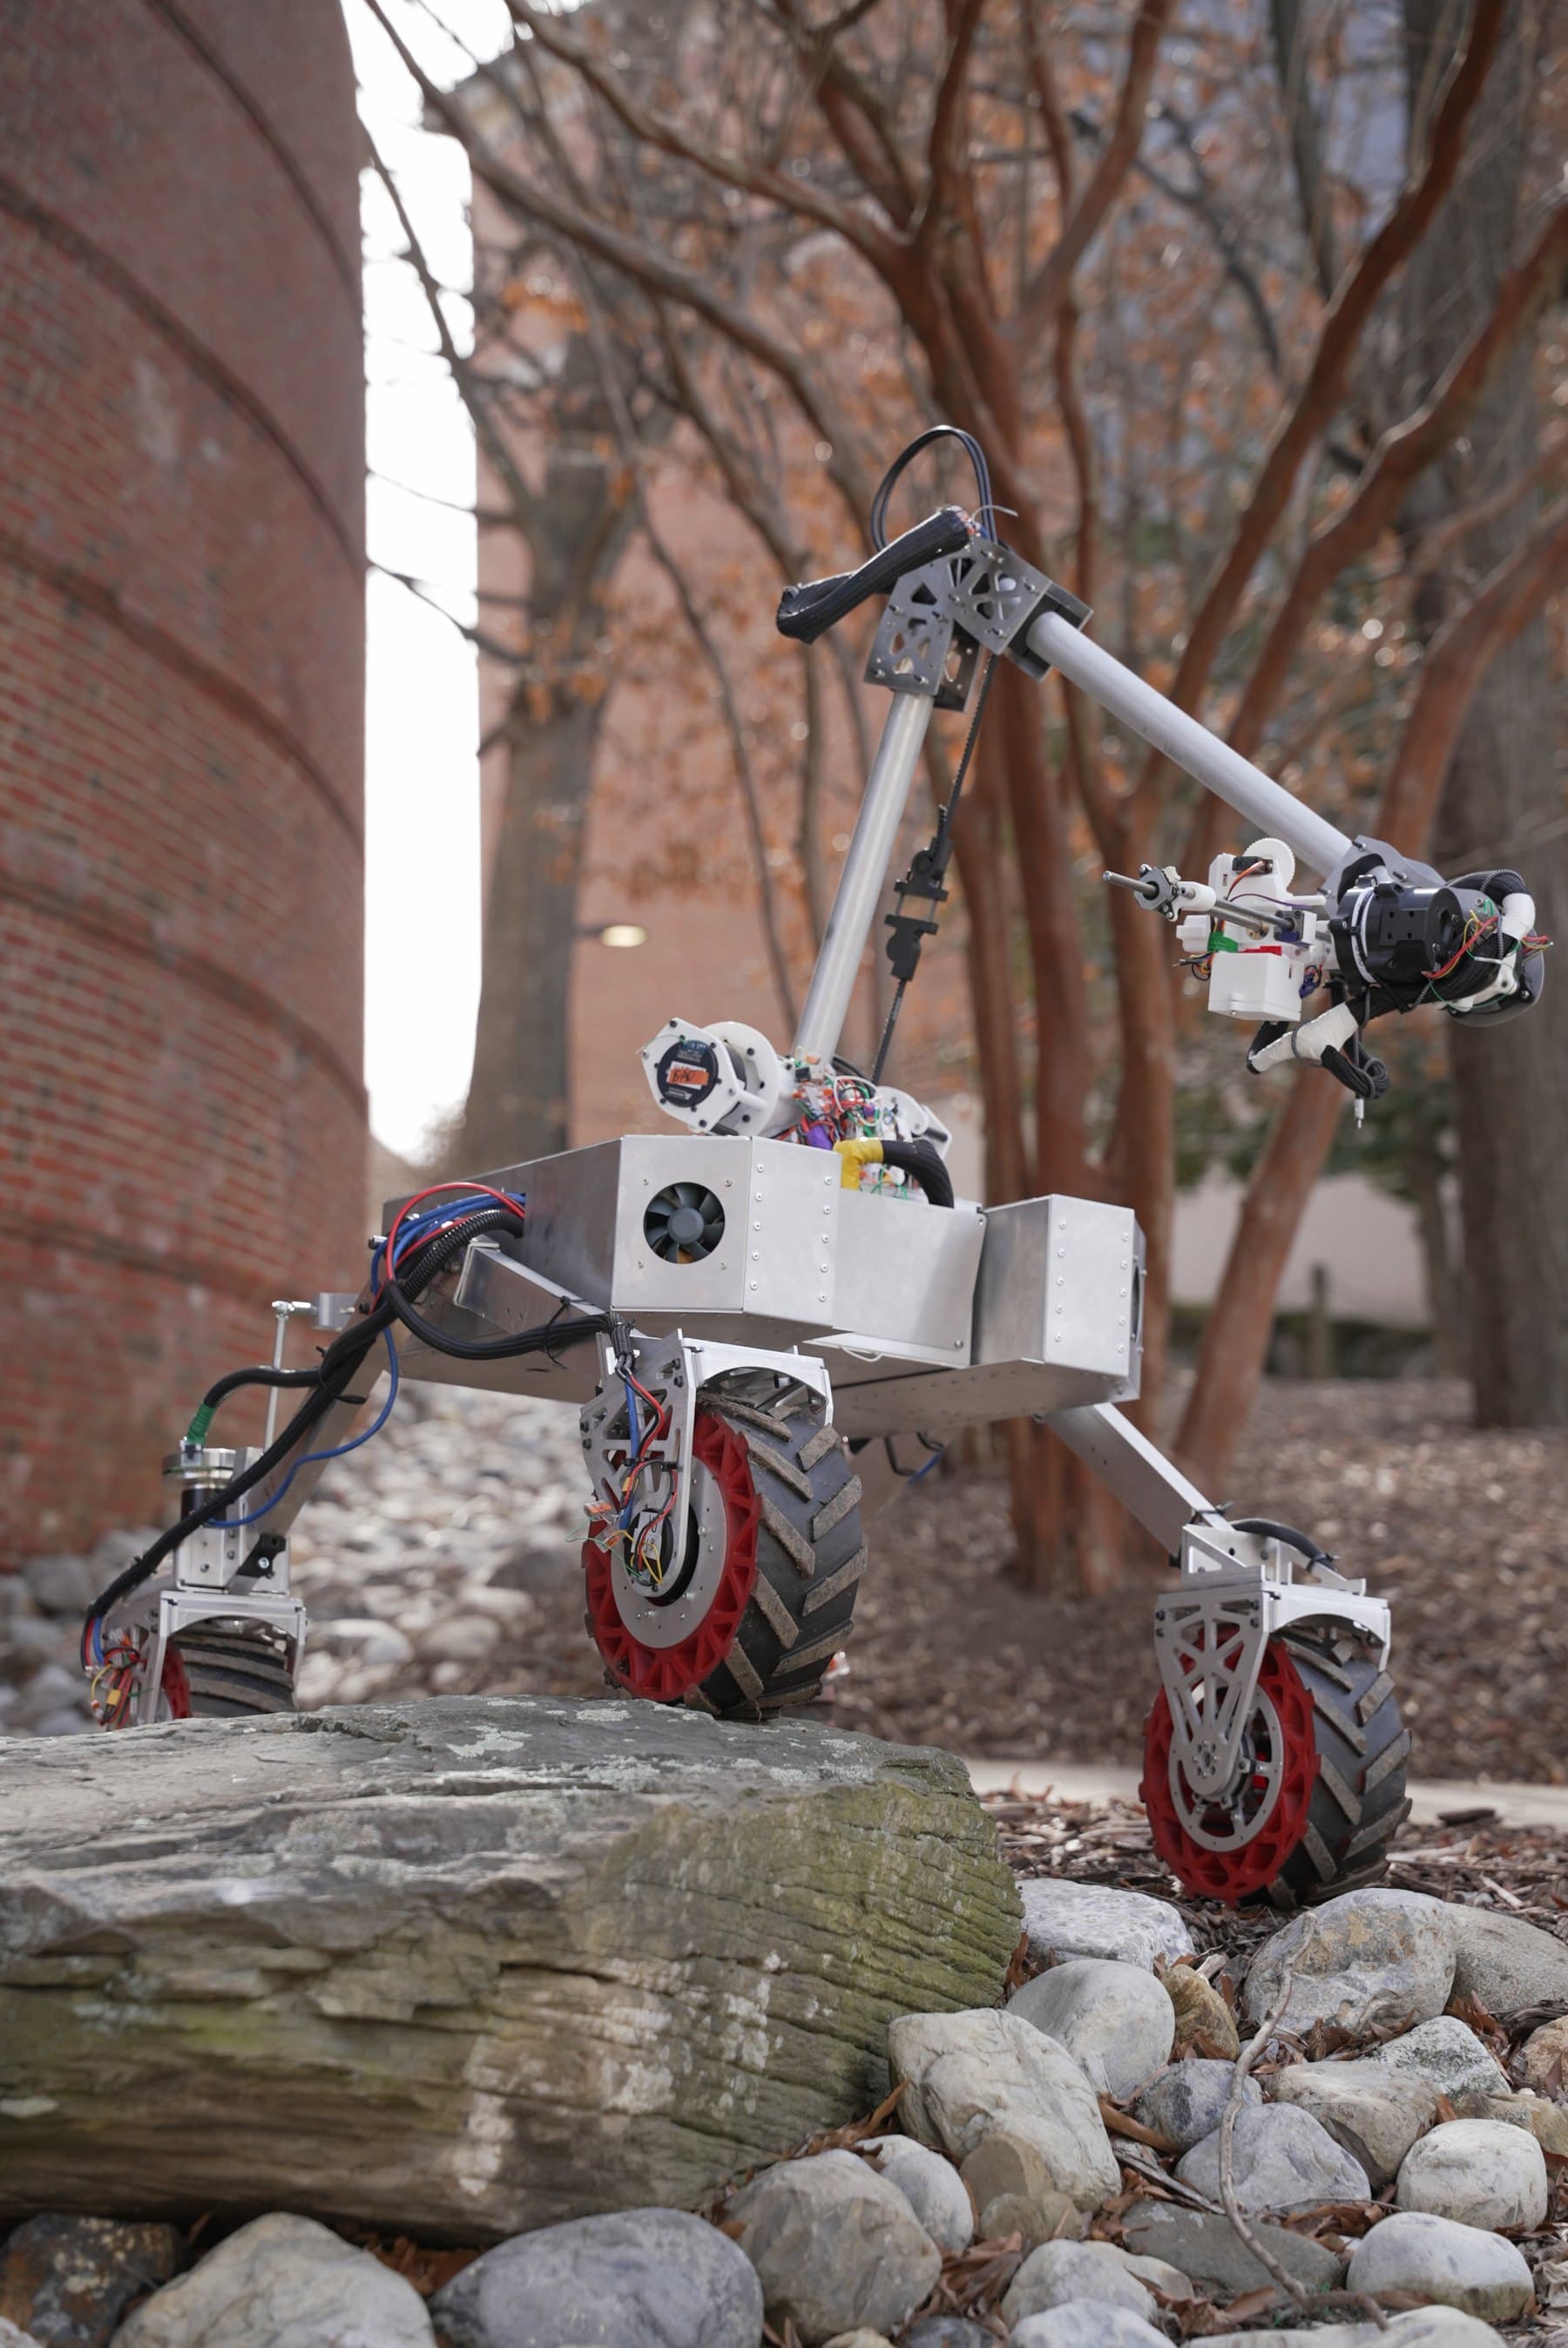
Ground systems
A wheeled platform carrying an arm, built around uneven ground: suspension, traction and picking things up once it arrives.
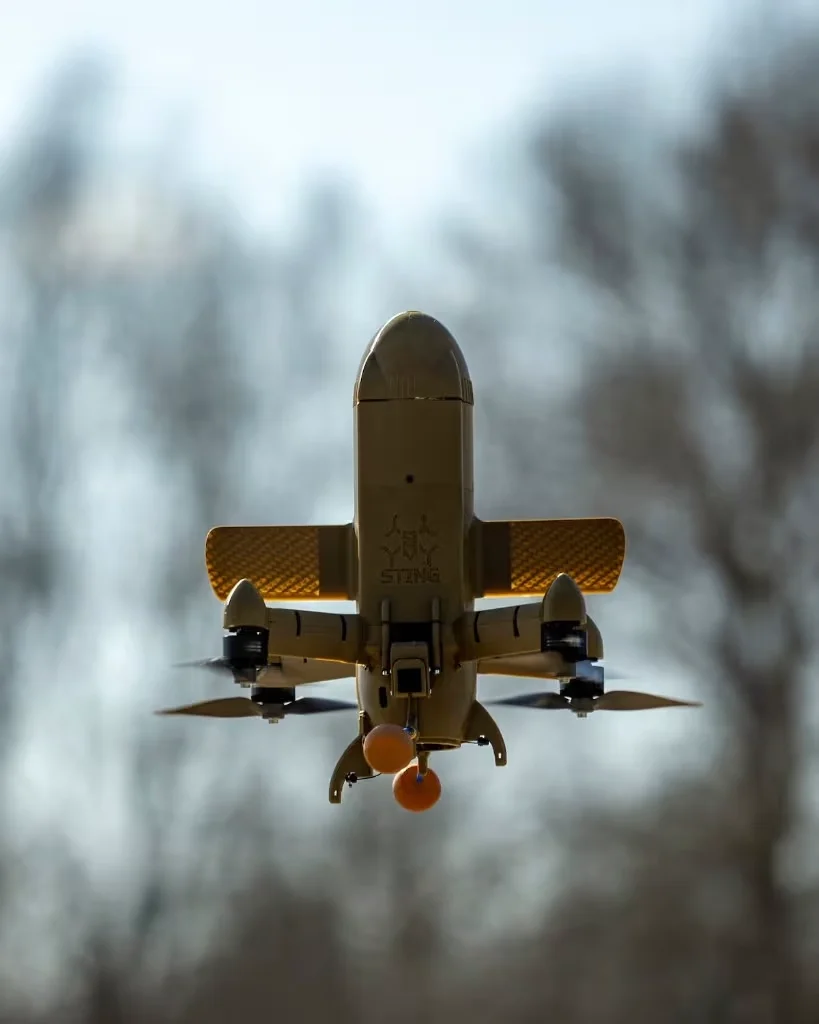
Drone systems
Quadcopters built for flight outside controlled conditions — airframe, tuning and stable flight in open terrain.
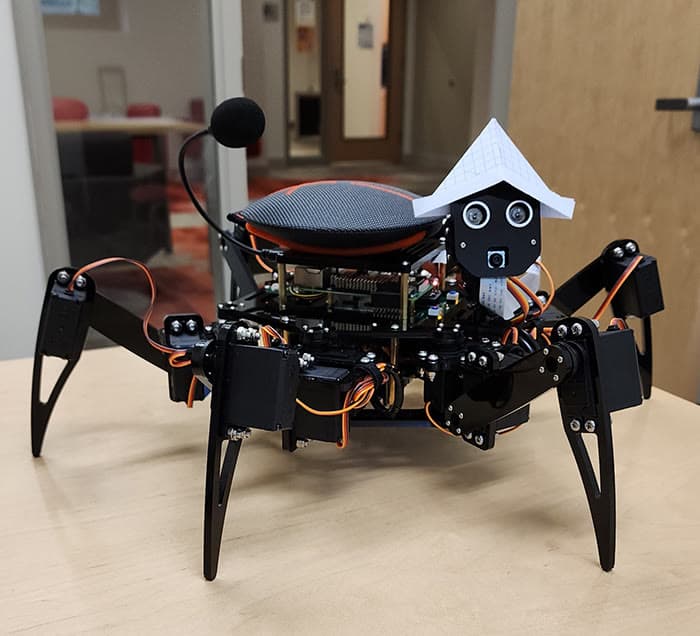
Legged robotics
A six-legged robot for gait generation and coordinating a large number of joints through a single controller.
Multi-robot systems
Work on several machines acting together: communication between units, formation keeping and shared state.
Drone systems
First-person-view airframes — the video link, the latency and the flying itself, which is its own engineering problem.
Engineering